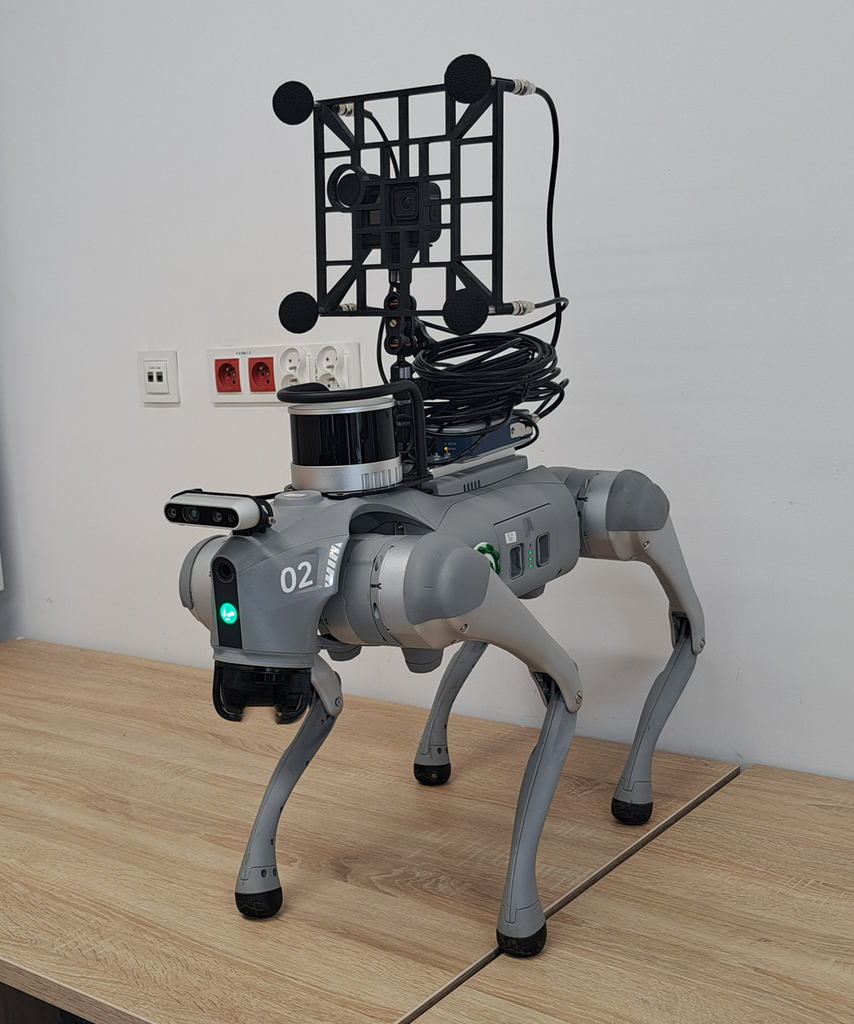
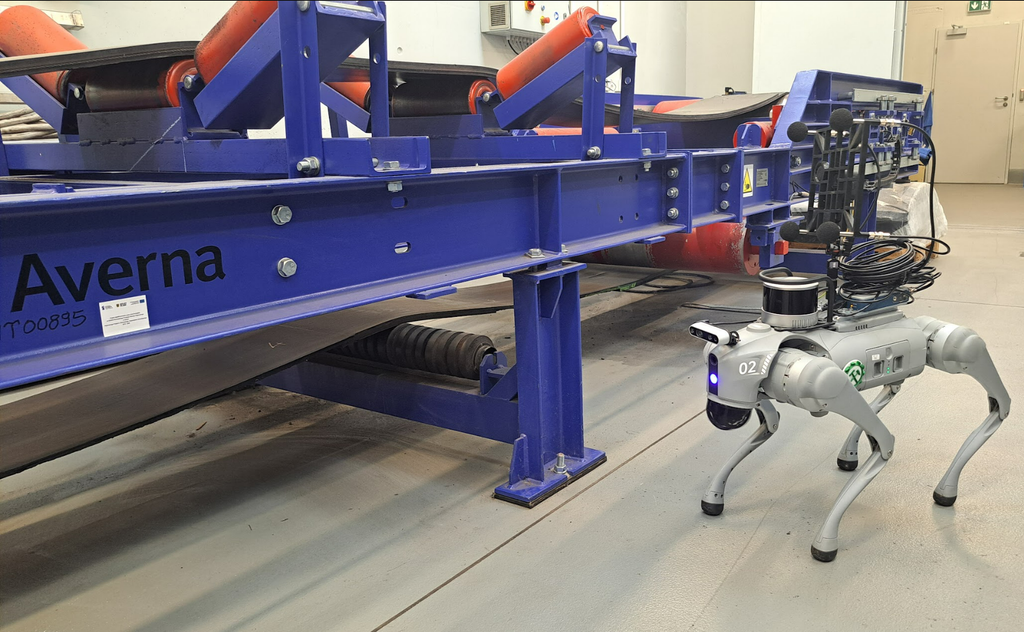
On 14 October 2026, the Digital Mining Center (DMC) team conducted the first integration and walkthrough test with Szarik in our faculty’s belt conveyor laboratories. The trial involved hardware compatibility testing of all equipment on the robot and a mobility resilience test while walking along the conveyor. These initial tests were carried out in preparation for research within the ongoing OPUS project, “Fusion of an inspection robot-based, non-contact measurements for sound driven condition monitoring of rolling element bearings under varying speed, harsh noise and uncertain experimental conditions.”
For this purpose, Szarik has been equipped with a microphone array for directional acoustic measurements, alongside additional sensors, including LiDAR scanners and cameras. This configuration will support research into the acquisition and fusion of acoustic, spatial, and visual data for robotic inspection. These initial trials mark the beginning of further experimental work aimed at developing and evaluating a multisensor robotic platform for industrial inspection.